Steps to use the online tuner
Start by opening the free online PID tuner.
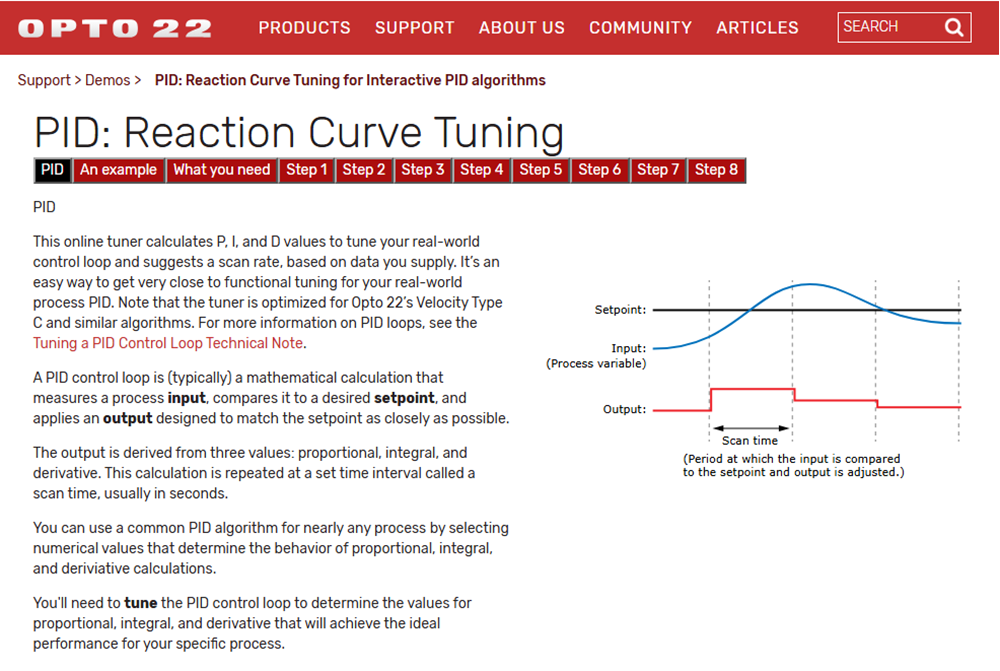
Free online PID tuner
In the tuner
The buttons at the top of the tuner explain PID loops and walk you through the process (the first three are explained in more detail in this article):
Tuning procedure
If you already have some rough tuning values for your PID loop, use them. If not, don’t worry; we start with the loop in manual. In either case the procedure is the same: we step the process from one steady state to another steady state, and capture the curve of the process in a graph that can be printed out on paper.
Use Step 1 in the tuner as a guide for the response curve graph that you need. If the curve of the process overruns the time scale of your graph the first time, reset the process, extend the time scale, and step through the process again. Or if the process is very responsive and the resulting curve is too compact to measure, reset the process and speed up the graph.
You may need to take a few trial runs at generating a nice clean curve on paper, but as you gain experience in using this tuning method, you’ll be faster at getting it right the first time.
Follow the steps
Step 1: Determine high and low values for the control variable (PID output).
Put the PID loop into manual and set the control variable (CV) PID output to a nonzero value. You may need to test this a few times to see what a good low output value is. Try to use a value of at least 10%. For example, with HVAC try a value around 20%.
Wait for the process to settle into a steady state. Then step the output to a higher value, typically 20–40% higher than the minimum. Allow the process to stabilize again. Use the image in the tuner as a guide of how the curve should look, and print the resulting graph.
In the tuner, enter the control variable higher (CV high) and lower (CV low) values—that is, the output value that you stepped to and the value you stepped from.
Step 2: Enter high and low values of your process variable (PID input).
In the tuner, enter the process variable high (PV high) and low (PV low) values for your PID input.
Step 3: Enter distance between steady states.
On your printout, measure the distance between the lower steady state of the control variable and the upper steady state (typically it’s easier to use millimeters rather than decimal inches as the distance units).
In the tuner, enter the distance between the two states. The amount of change in the control variable as a result of the step change is used to calculate the P term.
Step 4: Calculate the 63.2% point on the curve.
In the tuner, press the Calculate 63.2% change button. The tuner calculates the change and gives you the answer in a height from the lower steady state. Measure this height on your printout and mark the point on the curve. Drop a vertical line down from this point on the curve.
Step 5: Enter distance for the change.
Measure on your printout how long it took the process to change from its lower steady state to the 63.2% point on the curve. In the tuner, enter the distance you measured.
This distance will be converted to time in the next step so that we can determine the loop time constant. This is the amount of time that it took the input to move from its lower steady state to the 63.2% point of the input curve. This time tells us how dynamic the process is and is an important part of the Integral value calculation.
Step 6: Enter the time scale values.
On your graph, measure the distance between two known points of time. In the tuner, enter the Time scale in time units (the scale you used, in seconds) and the Time scale on paper (the distance you measured, in millimeters).
Step 7: Determine the loop dead time.
On your graph, measure the distance between the step change in the output and the beginning of change in the input. In the tuner, enter this process loop Dead time, which is the amount of time it takes the process to begin to react to a change.
Dead time is an important part of understanding how frequently you should set the PID controller to perform its loop calculation. The online tuner calculates a PID scan rate that sets the loop to scan four times during the loop dead time interval you enter.
Step 8: Get the final calculations.
The tuner now has all the data it needs to calculate the P, I and D values for you and to suggest a scan time. Press the Calculate tuning button and write down the results. This provides a starting point for tuning your PID loop.
If you want to understand the process that the tuner uses to compute those numbers, check the Show calculation box.
Here's an example of the result:
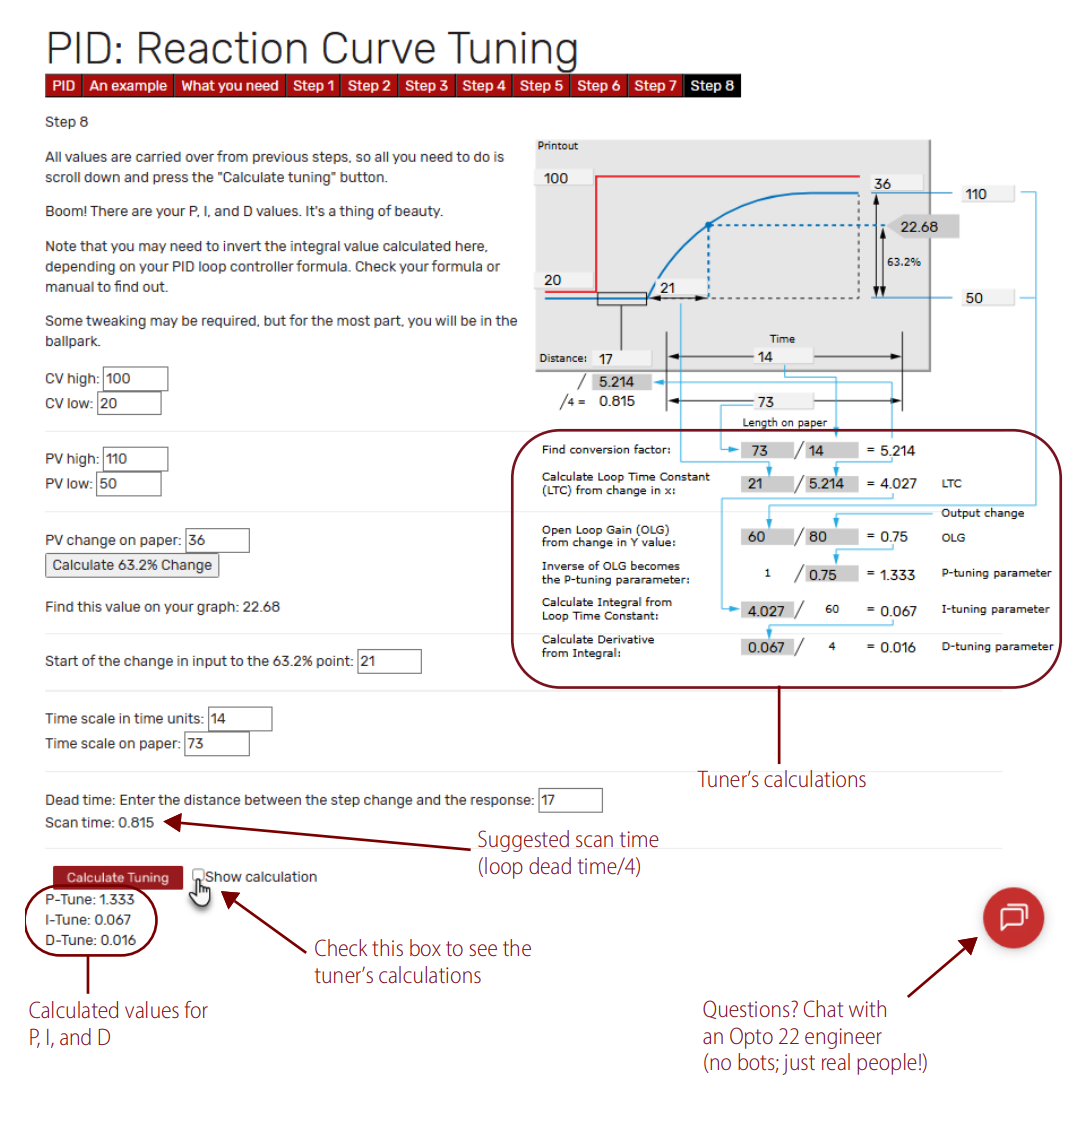
Example: results of tuning a PID loop with the free online tuner
For each PID loop, we suggest using the free online tuner to get a rough baseline for P, I, D, and scan time.
Need help using the PID online tuner? Contact Opto 22 Product Support or talk to an engineer—it's free!